
Works
Projects
Three pieces of the chain, each one published or in use.

BRIX
An autonomous system for brick wall construction: a 650 kg rover carrying a collaborative Fanuc arm, built to work on an open construction site rather than inside a structured industrial cell.
Validated with a full-scale demonstrator at SAIE 2023 and assessed with CARSAM across environmental, social, technological and economic dimensions. The strongest result is in occupational safety; upfront cost and the policy support the market would need remain open.
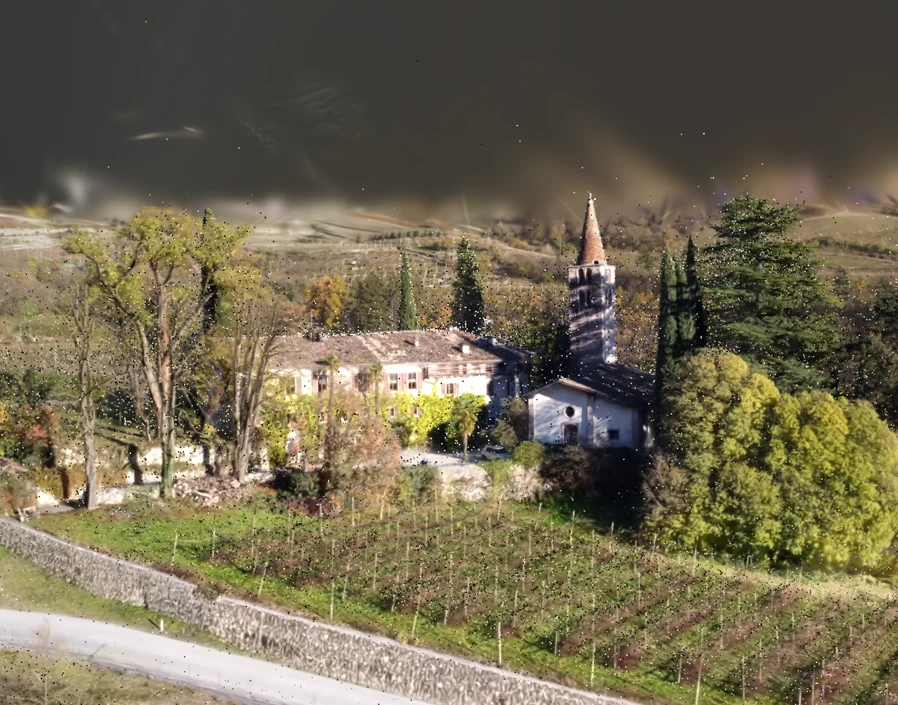
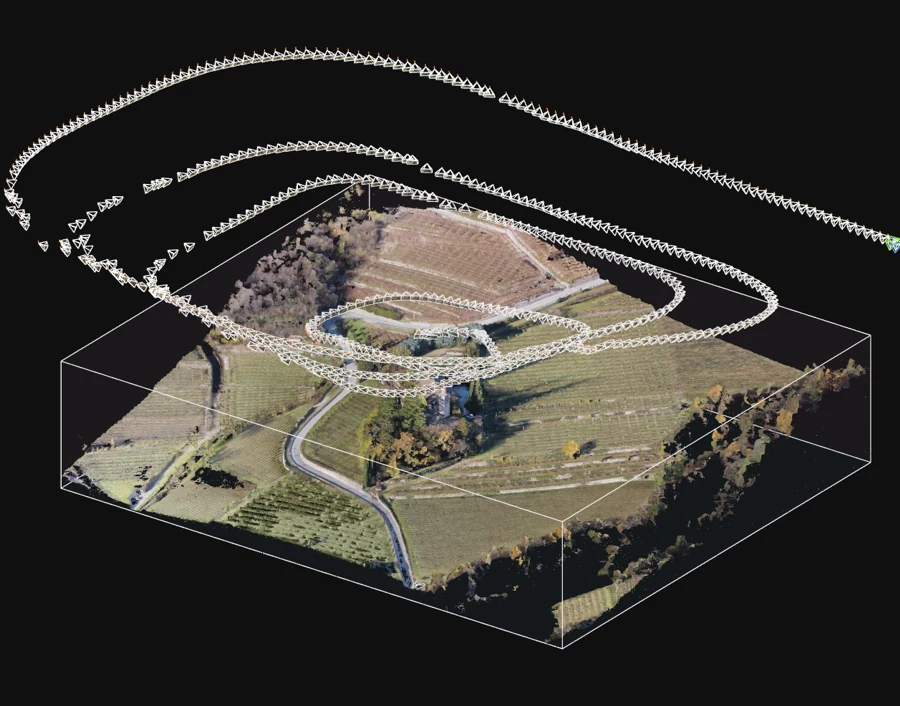
Gaussian splatting from the drone survey
Survey with Gaussian splatting
A hillside settlement flown by drone and reconstructed as a Gaussian splatting model. Low-cost photogrammetry and splatting were run on the same site and compared for what survives the passage into an interactive environment, and at what cost.
The flight path is planned before the survey, and the records that come out of it are tied to a persistent registry, so each unit carries an identity and not only a shape. The model is then the base for the participatory design work.
Fanuc cell toolpathing
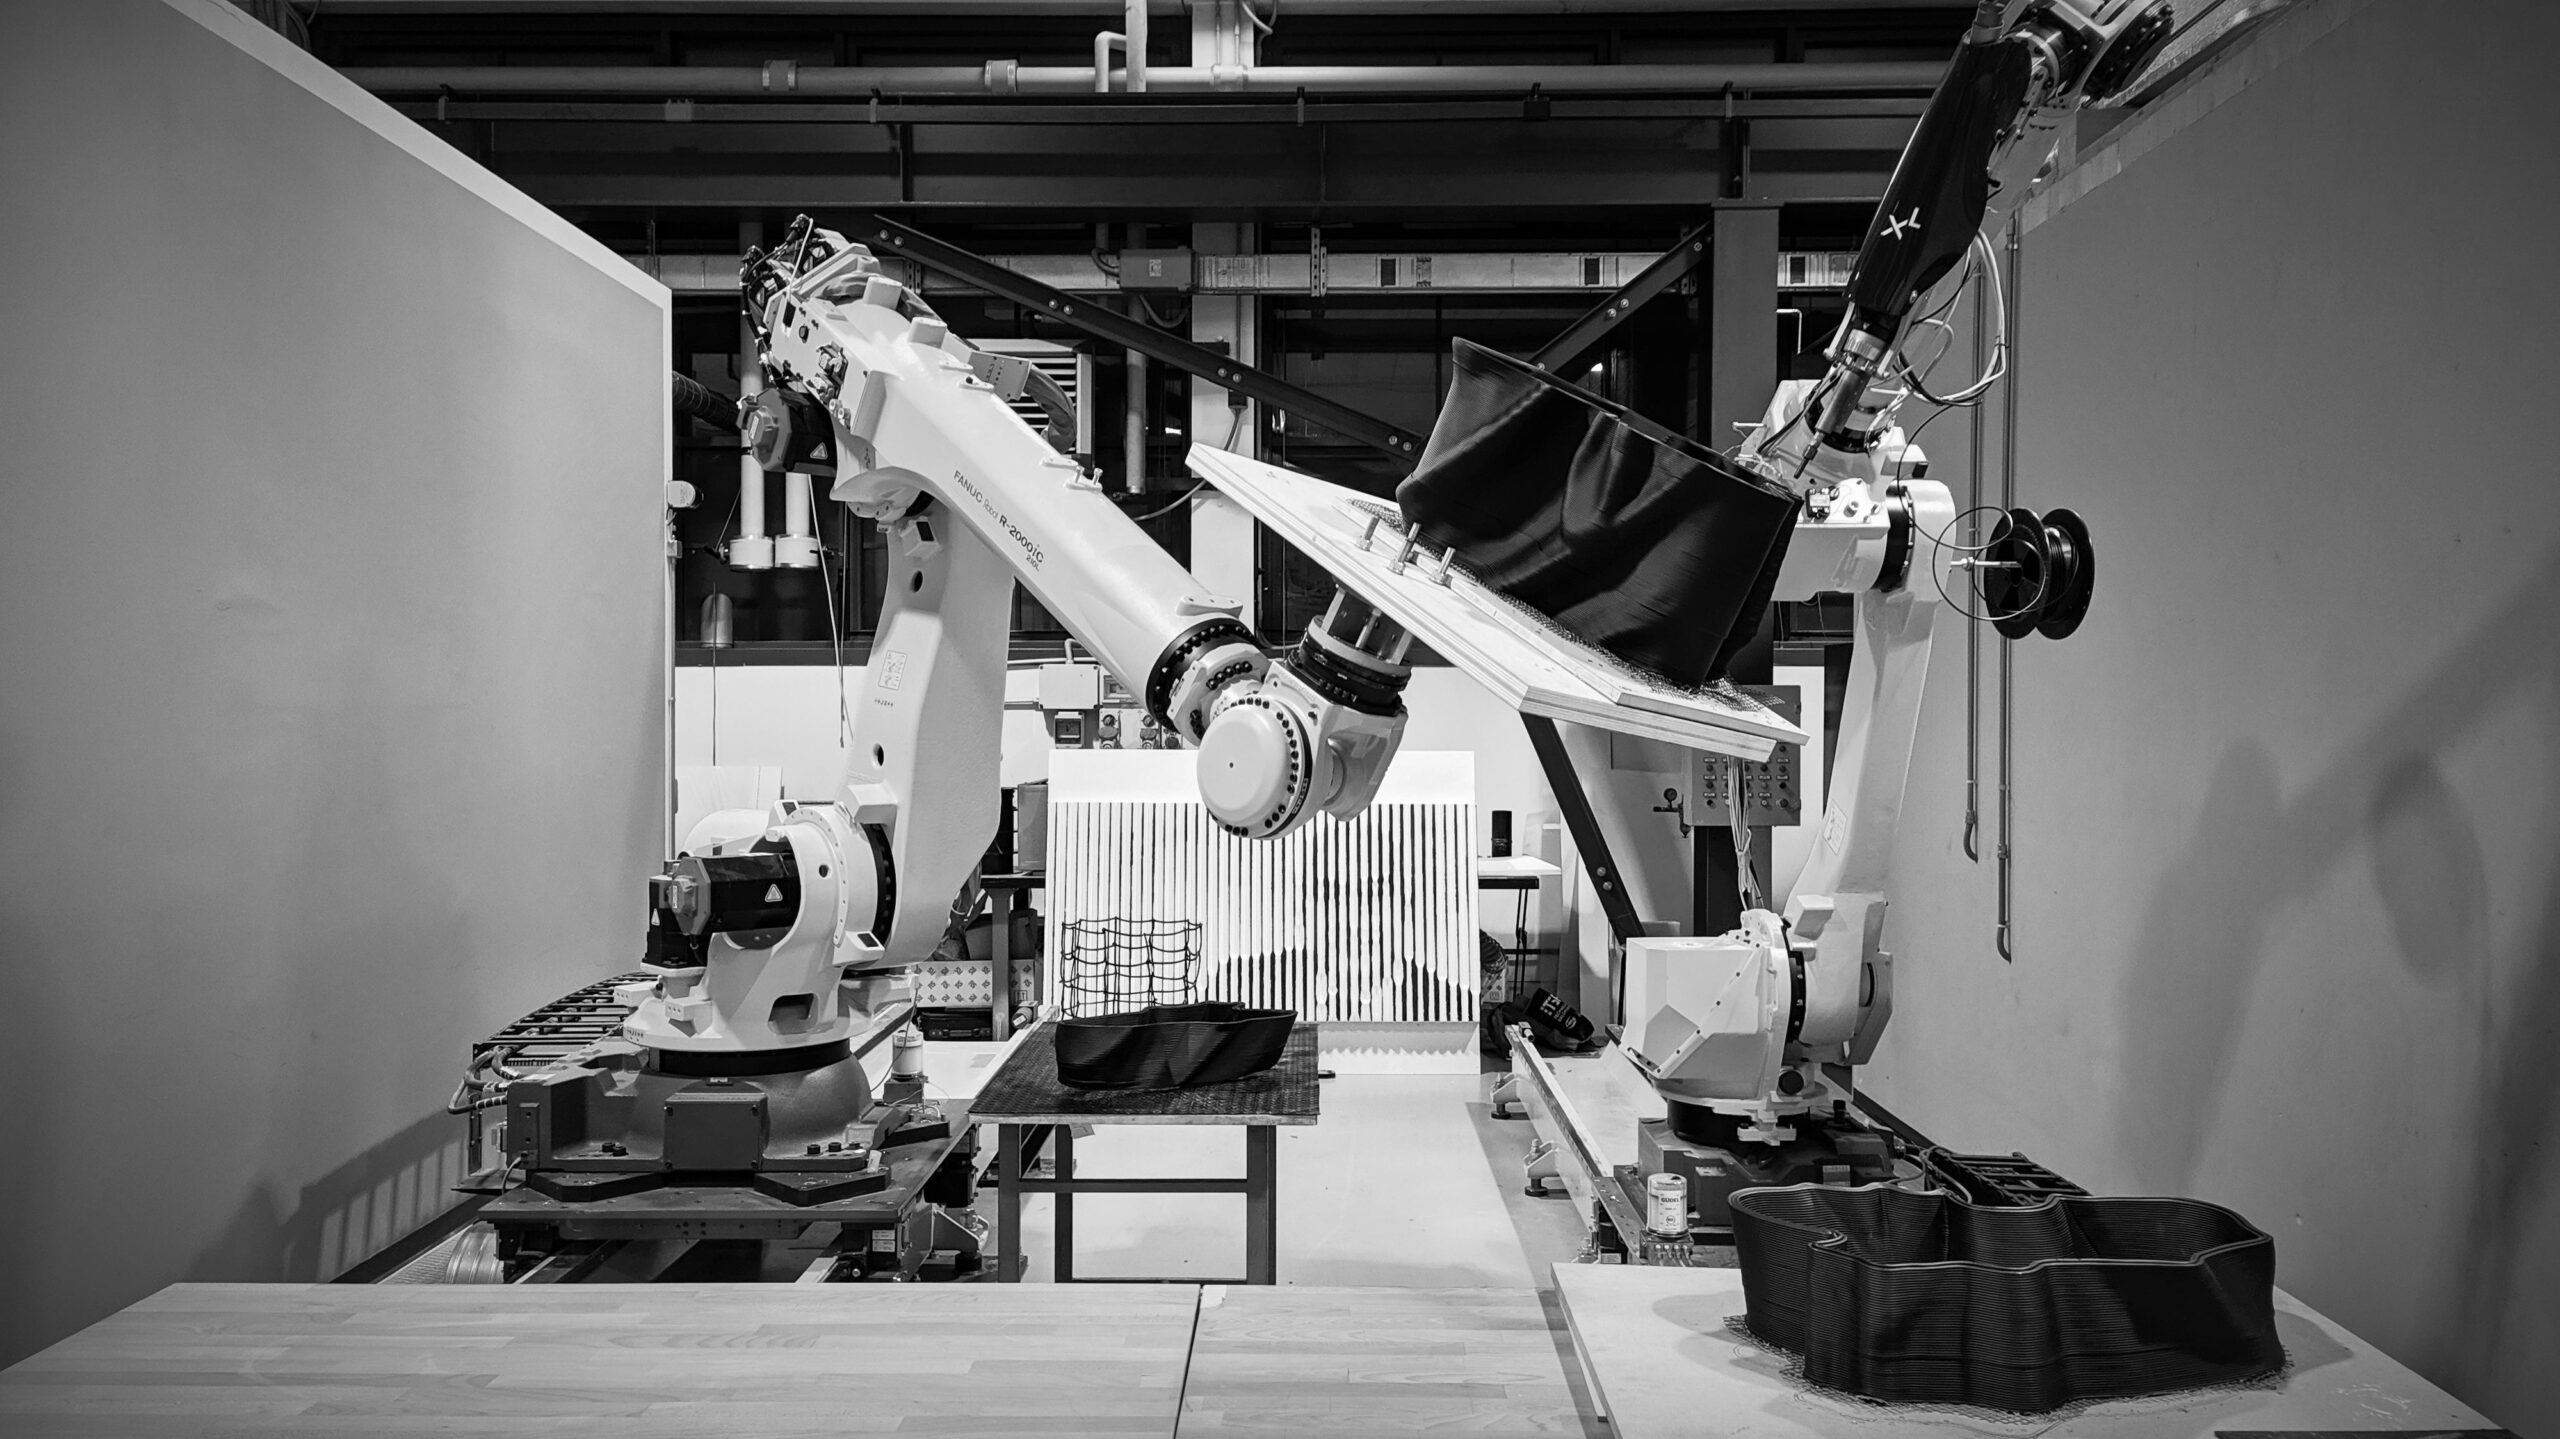
A fork of the Robots plugin for Rhino 8 and Grasshopper, extending its Fanuc post-processor for the Indexlab cell: an R2000iC and an M710iC on Güdel rails under an R-30iB controller, emitted as multi-group .LS programs.
The rail axes are handled as part of the kinematic chain, so a toolpath generated in the model becomes a program the controller accepts without a manual translation step.